
OpenPodCar_V2, an open-source autonomous vehicle platform
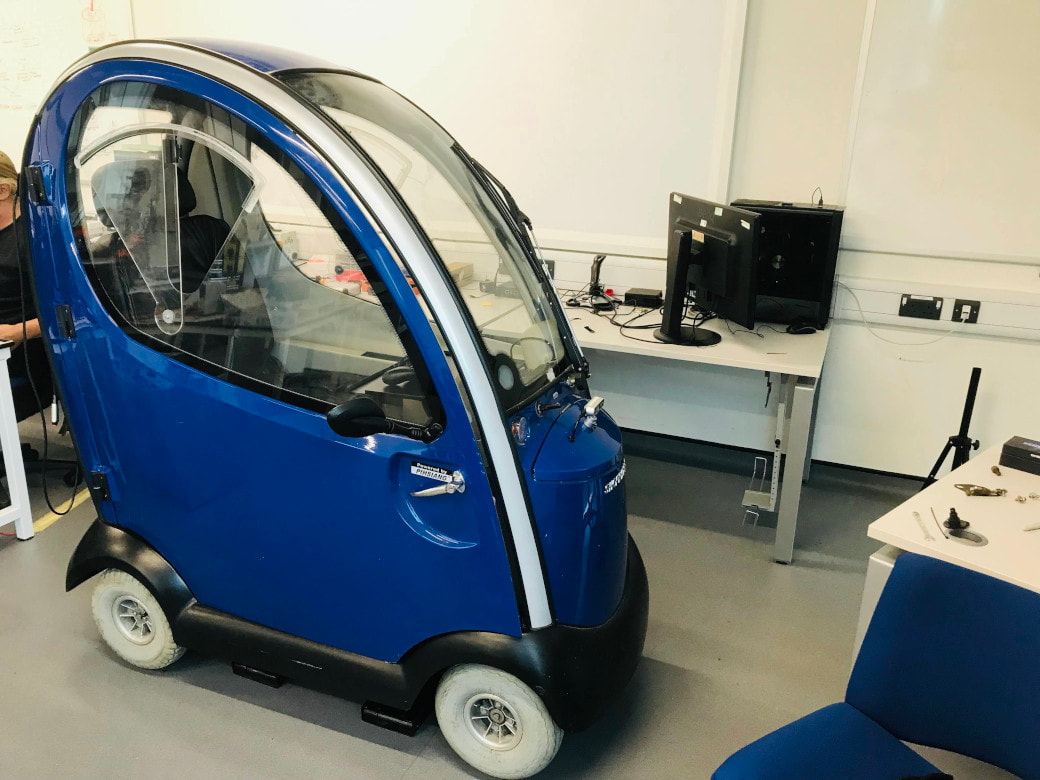
A low-cost autonomous vehicle built from a commercial mobility scooter, with open hardware and a full ROS2 software stack for human–AV interaction research.
Challenge
The original OpenPodCar ran on ROS1, with SVM and Bayes-tracking detection that had become outdated for current research.
Approach
Rebuilt the stack on ROS2: integrated NAV2 for the physical vehicle and a matching Gazebo simulation behind one ROS2 interface, plus visual SLAM and RGB-D odometry (RTAB-Map) from a single Intel RealSense D435 camera.
Outcome
Mapping and localisation with reasonable accuracy across large indoor and outdoor areas, including loop closures. Presented as a poster at the University of Lincoln College of Science event, June 2023.